Hyundai Ioniq (AE): Lubrication System / Oil Pump. Repair procedures
| Removal and installation |
| 1. | Remove the timing chain cover. (Refer to Timing System - "Timing Chain Cover") |
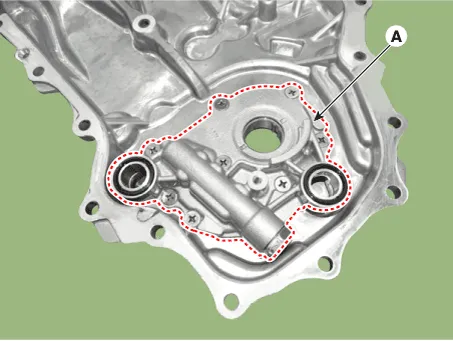
| 2. | Remove the oil pump cover (A).
|
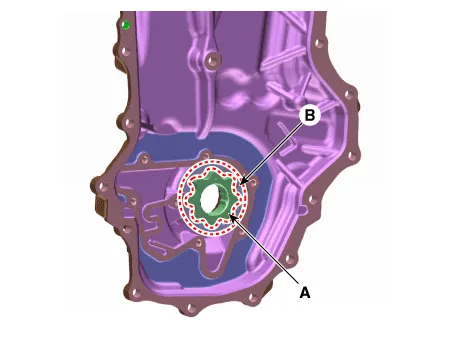
| 3. | Remove the inner rotor (A) and outer rotor (B).
|
| 4. | Install in the reverse order of removal. |
| Inspection |
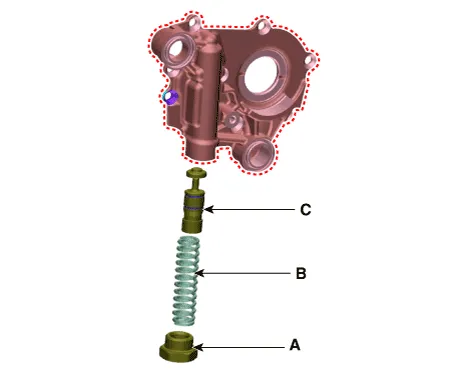
| 1. | Remove the relief plunger. Remove the plug (A), spring (B) and relief plunger (C).
|
| 2. | Inspect the relief plunger. Coat the plunger with engine oil and check that it falls smoothly into the plunger hole by its own weight. If necessary, replace timing chain cover. |
| 3. | Inspect the relief valve spring. Inspect for distortion or breakdown of the relief valve spring. |
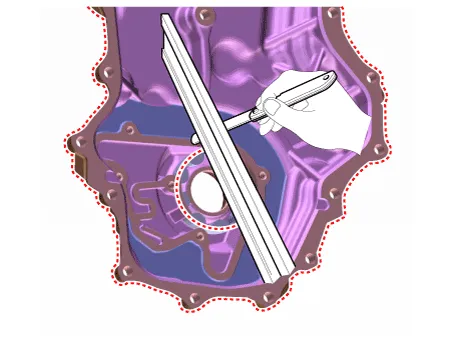
| 4. | Inspect the rotor side clearance. Using a feeler gauge and precision straight edge, measure the clearance between the inner rotors and precision straight edge. If the side clearance is greater than maximum, replace the rotors as a set. If necessary, replace the timing chain cover.
|
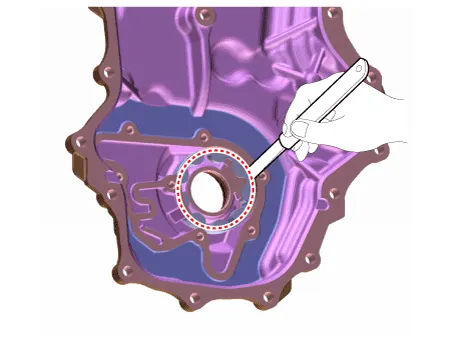
| 5. | Inspect the rotor body clearance. Using a feeler gauge, measure the clearance between the outer rotor and body. If the body clearance is greater than maximum, replace the rotors as a set. If necessary, replace the timing chain cover.
|
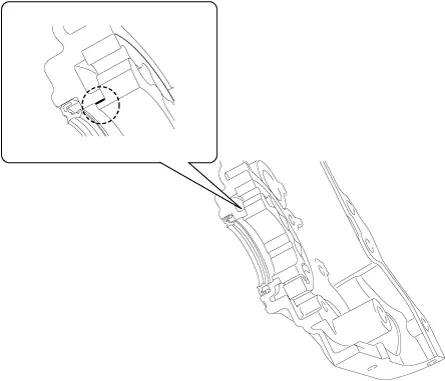
| 6. | Inspect the rotor guide clearance.
|
Components1. Inner rotor2. Outer rotor3. Oil seal4. Plug5. Relief spring6. Relief plunger7. Oil pump cover8. O-ring
Removal and Installation1.Disconnect the battery negative terminal.2.Remove the engine room under cover.(Refer to Engine and Transaxle Assembly - "Engine Room Under Cover")3.
Other information:
Hyundai Ioniq (AE) 2017-2022 Service & Repair Manual: Heater Unit. Repair procedures
Replacement When prying with a flat-tip screwdriver or use a prying trim tool, wrap it with protective tape, and apply protective tape around the related parts, to prevent damage.1.Disconnect the negative (-) battery terminal.2.Recover the refrigerant with a recovery / recycling / charging station.
Hyundai Ioniq (AE) 2017-2022 Service & Repair Manual: Description and operation
System OverviewParking Distance Warning (PDW) is an electronic driving aid that warns the driver to be cautious while parking or driving at low speed. The sensor uses ultrasonic waves to detect objects within proximity of the vehicle.PDW consists of four RPS sensors which are detecting the obstacles and transmit the result separated into three war
Categories
- Manuals Home
- Hyundai Ioniq Owners Manual
- Hyundai Ioniq Service Manual
- Engine Clutch System
- Body (Interior and Exterior)
- Suspension System
- New on site
- Most important about car
